Industrial Parallel Robot (Delta / Spider) Joint Connector & Mechanical Hand Bracket
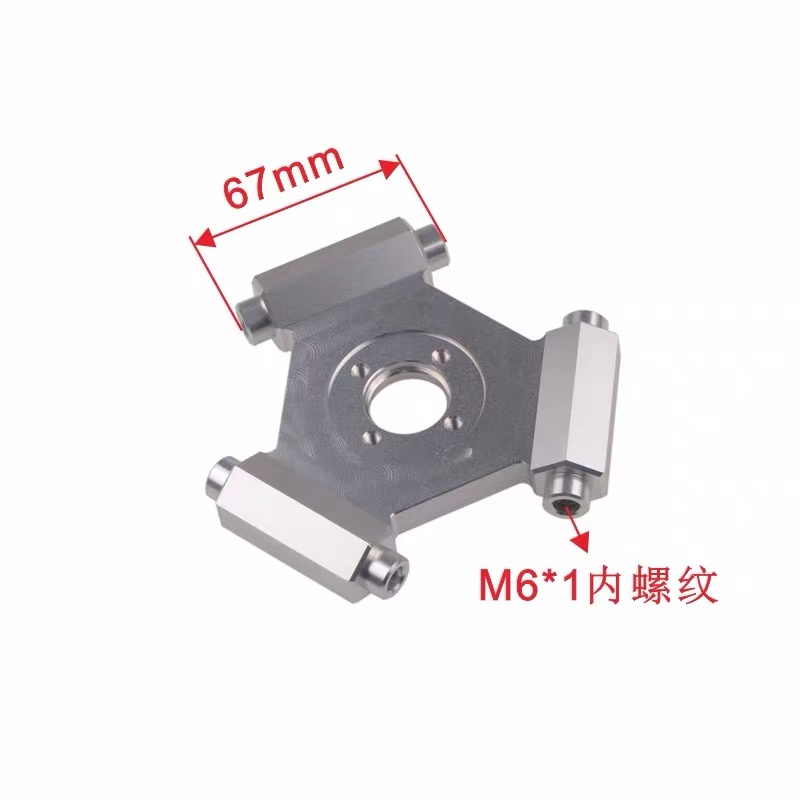
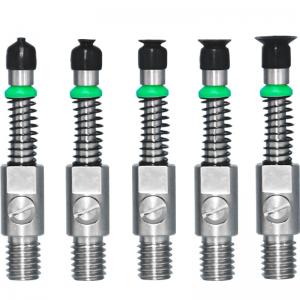
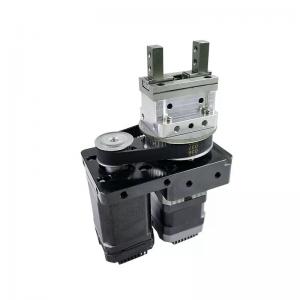
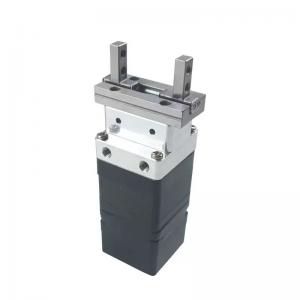
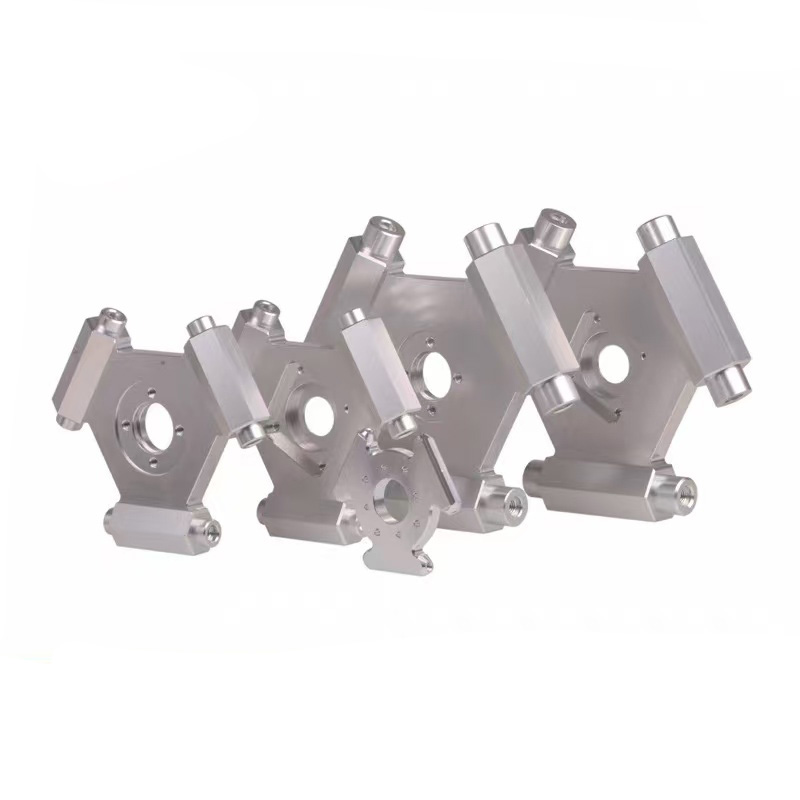
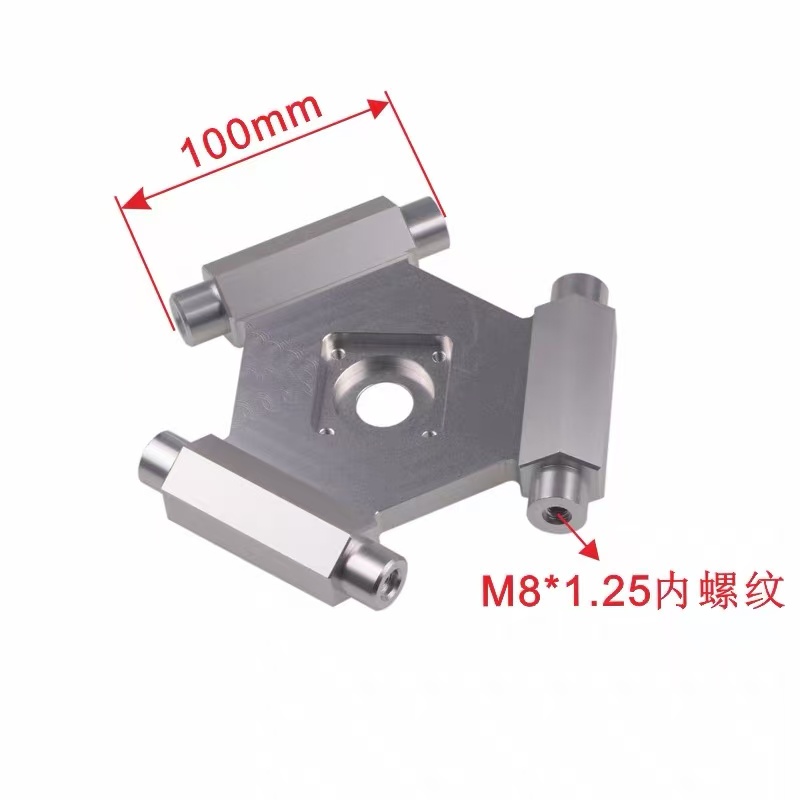
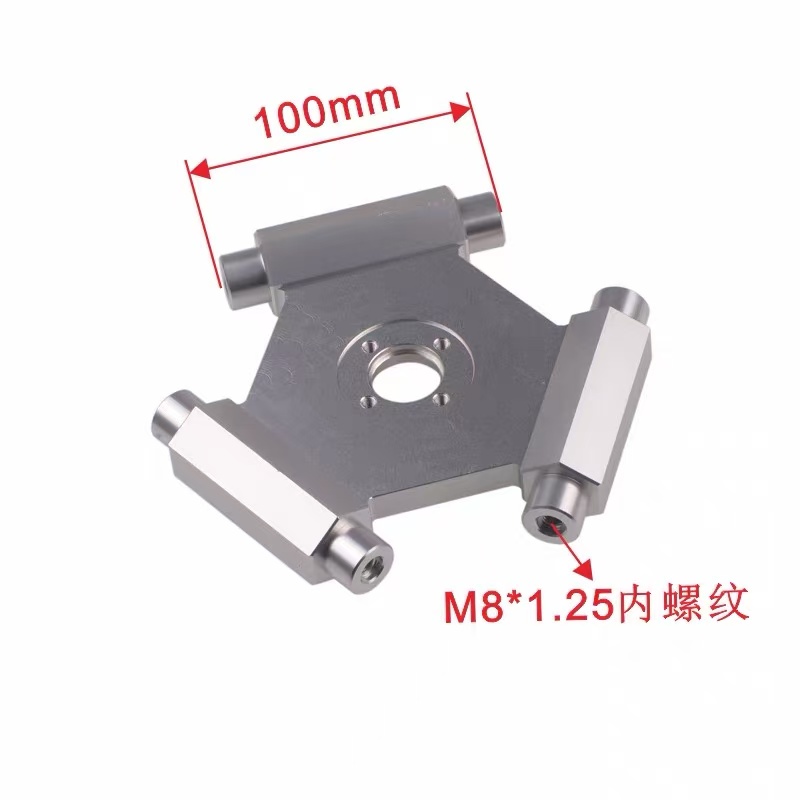
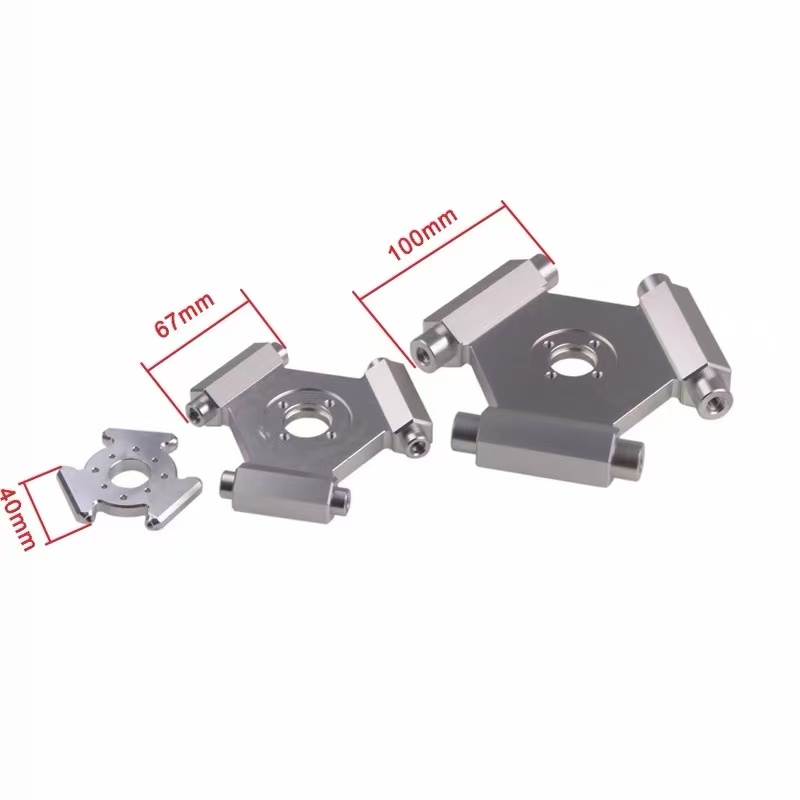
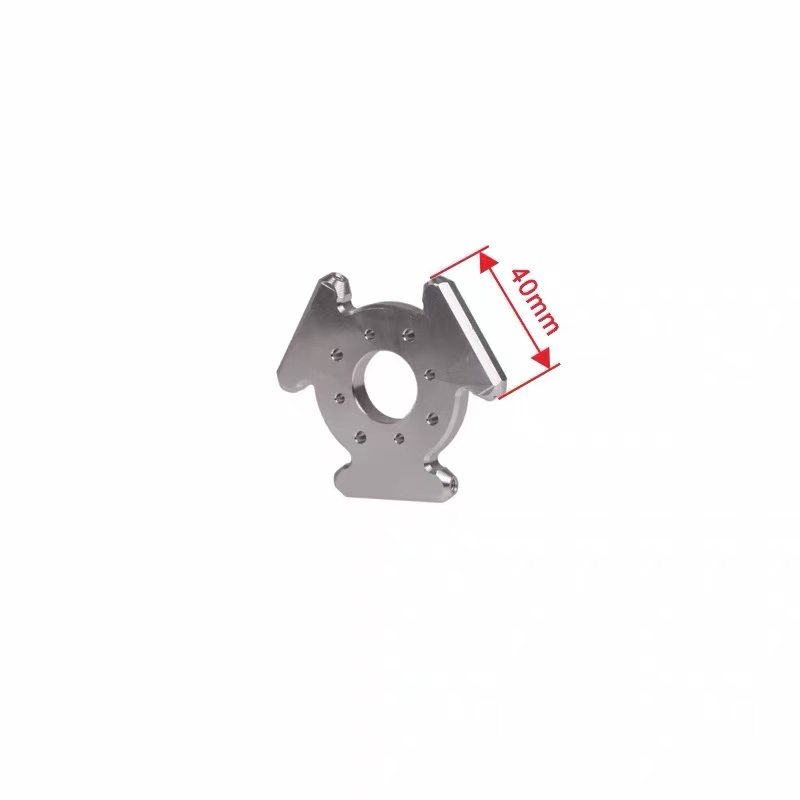
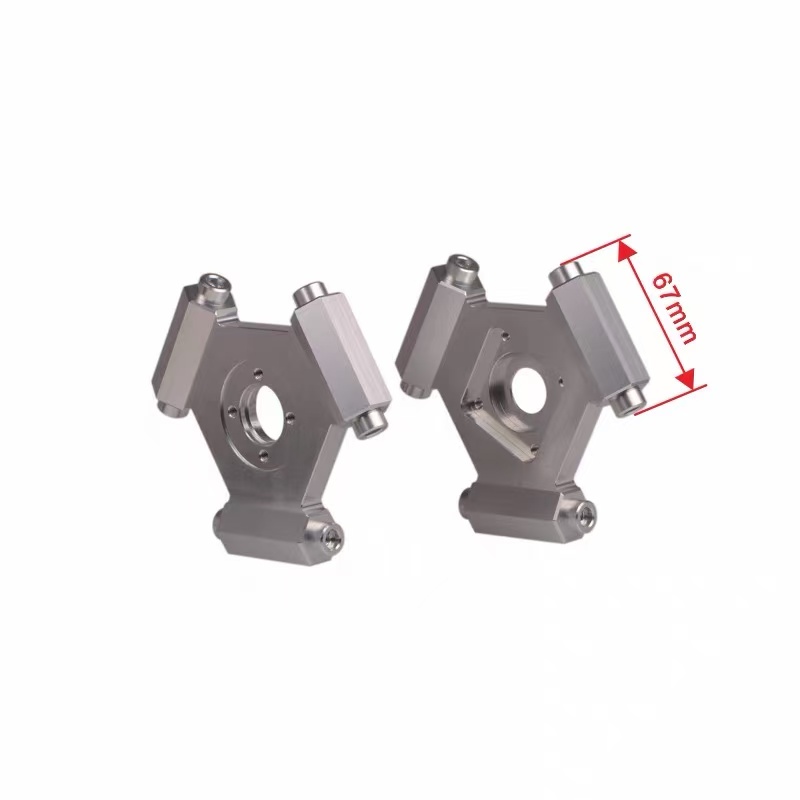
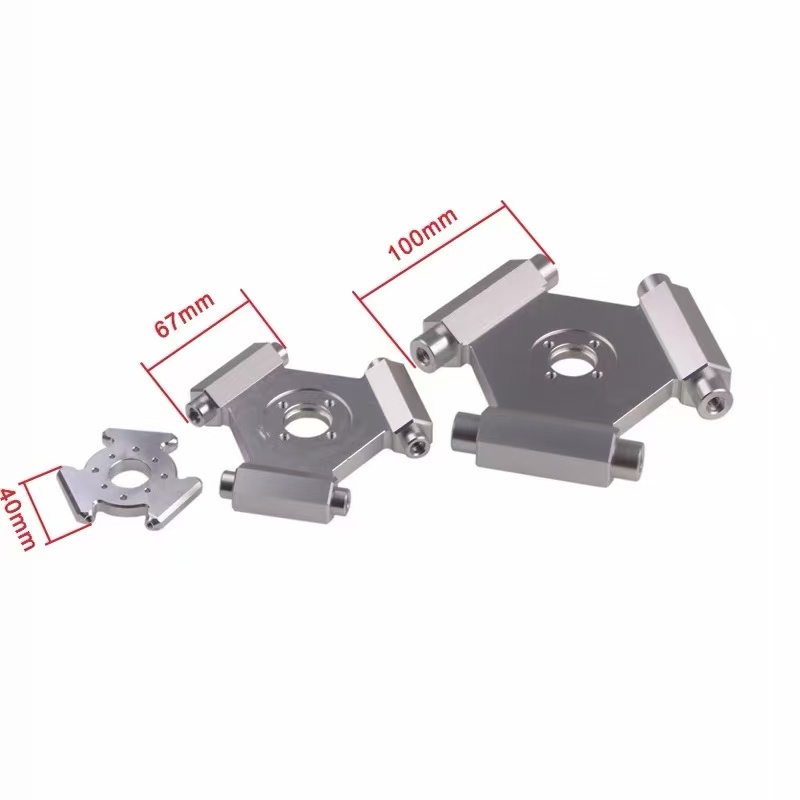
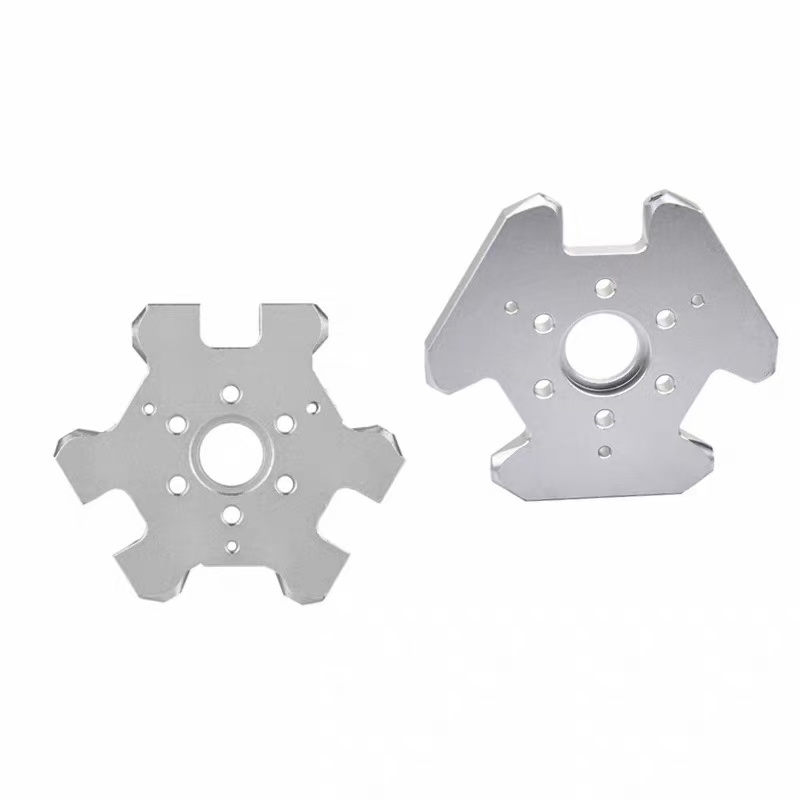
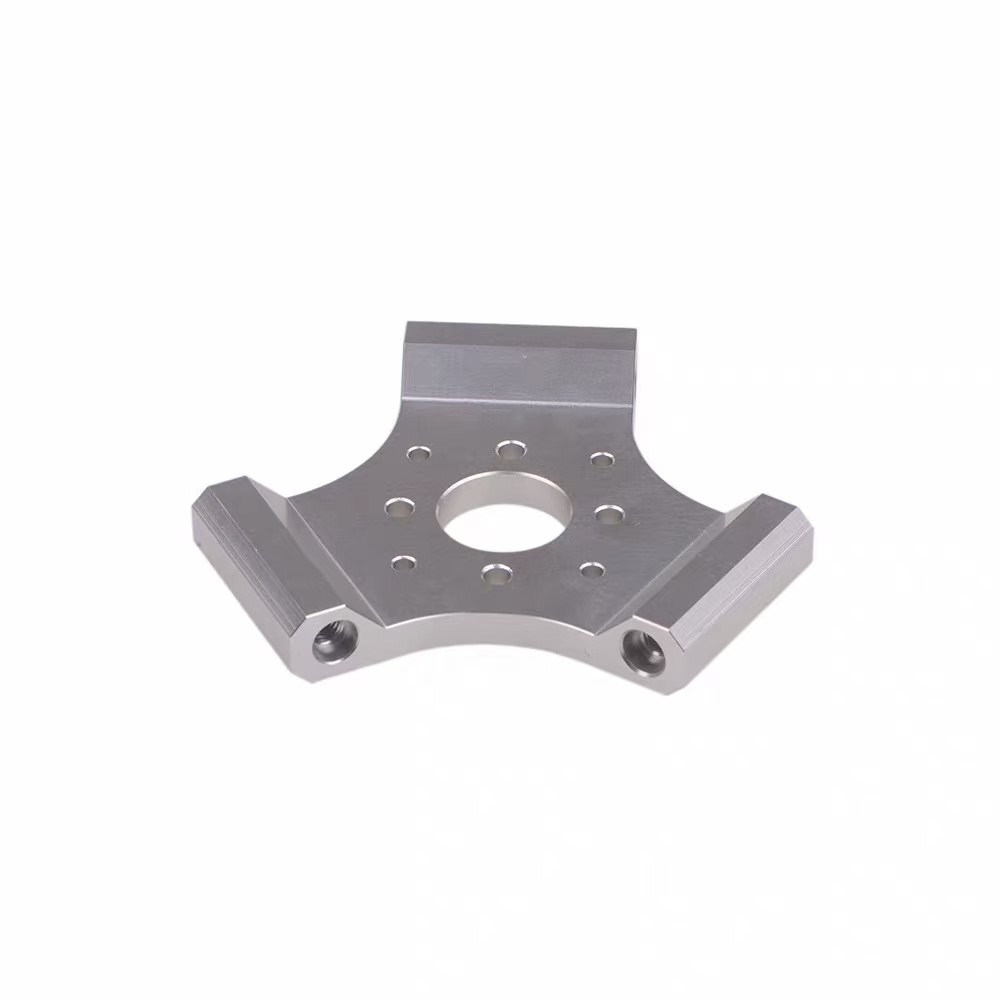
The product is a end-effector mounting base and hinge joint bracket designed for Industrial Parallel Robots (Delta Robots / Spider Robots). It serves as a connector between the secondary arms of the robot and the end-effector (such as grippers, suction cups, or custom tooling), widely used in high-speed sorting, packaging, and light industrial automation lines.
Aluminum machined delta robot end effectors
M3 screw
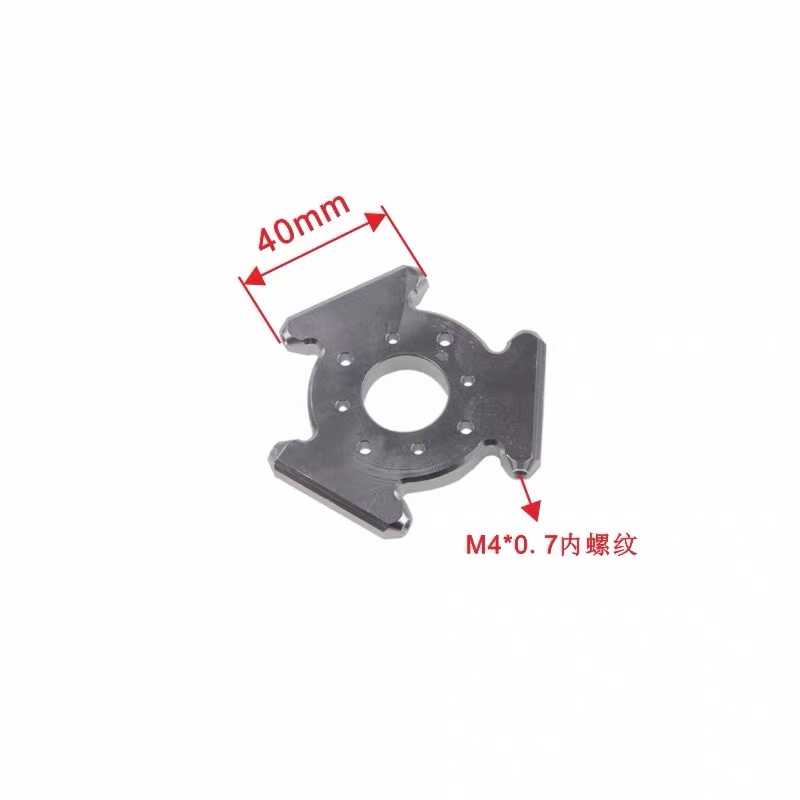
M4 screw
2026 New arrival for parallel robot or industrial spider pick and place robot
PRE40-M4
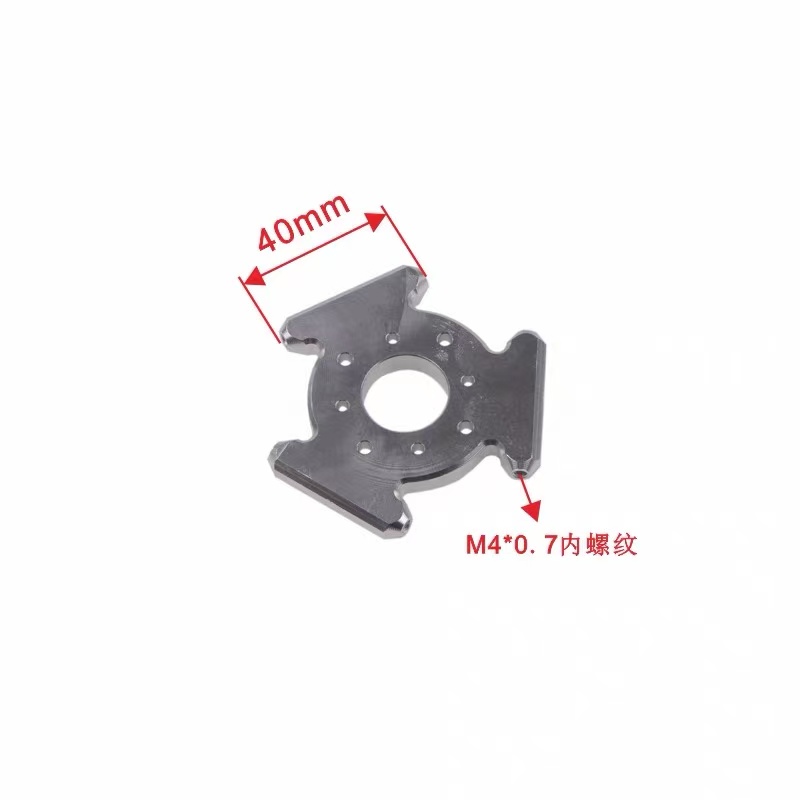
PRE40-M442
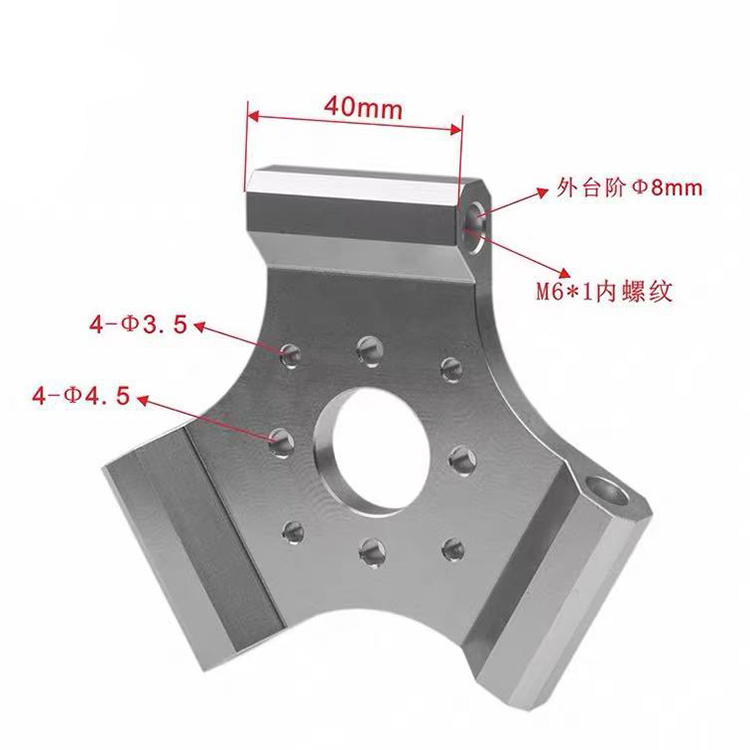
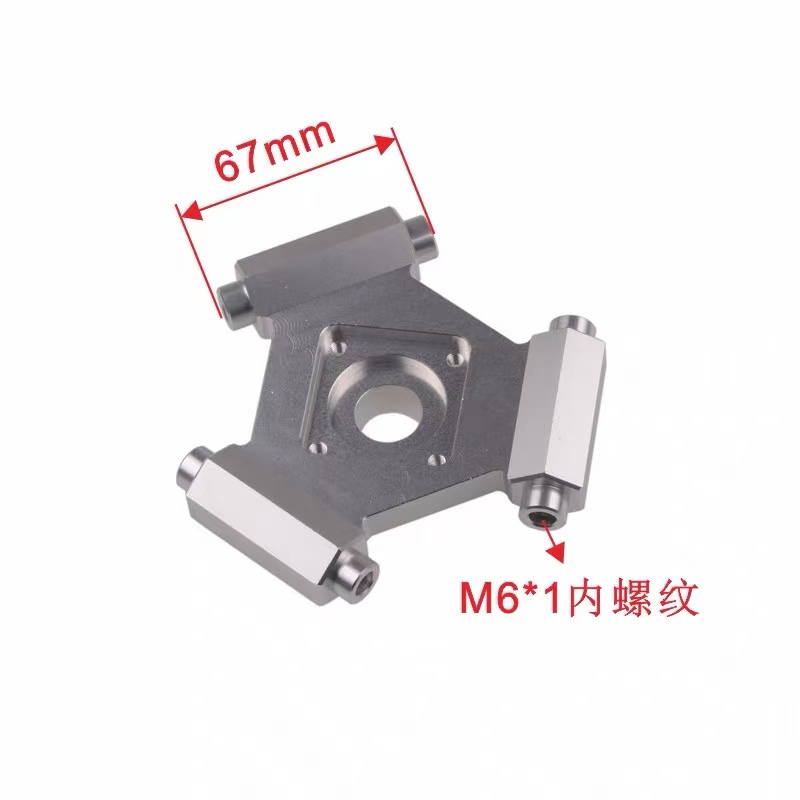
PRE67-M6S
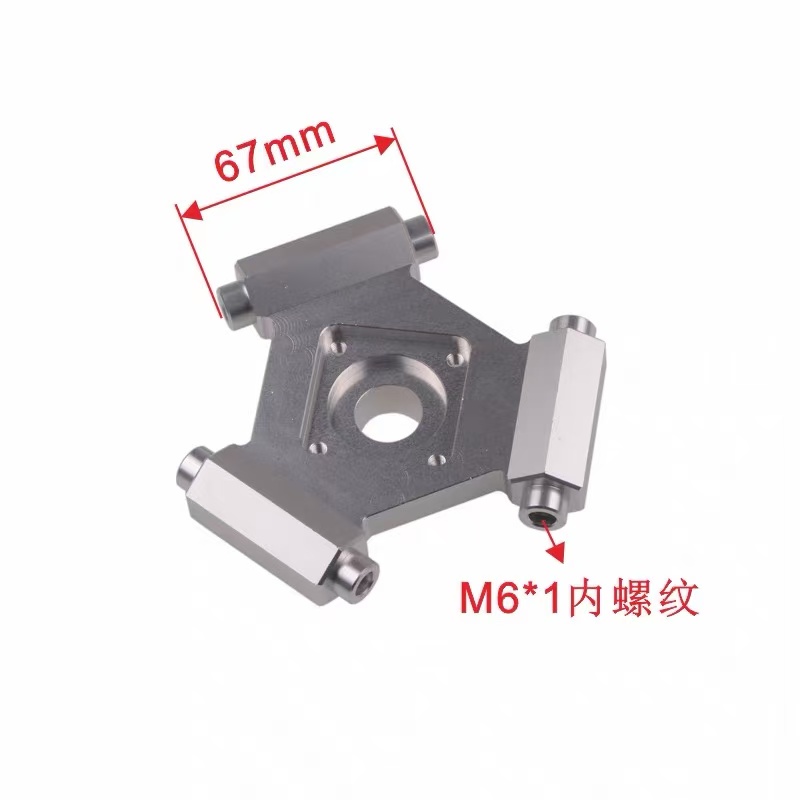
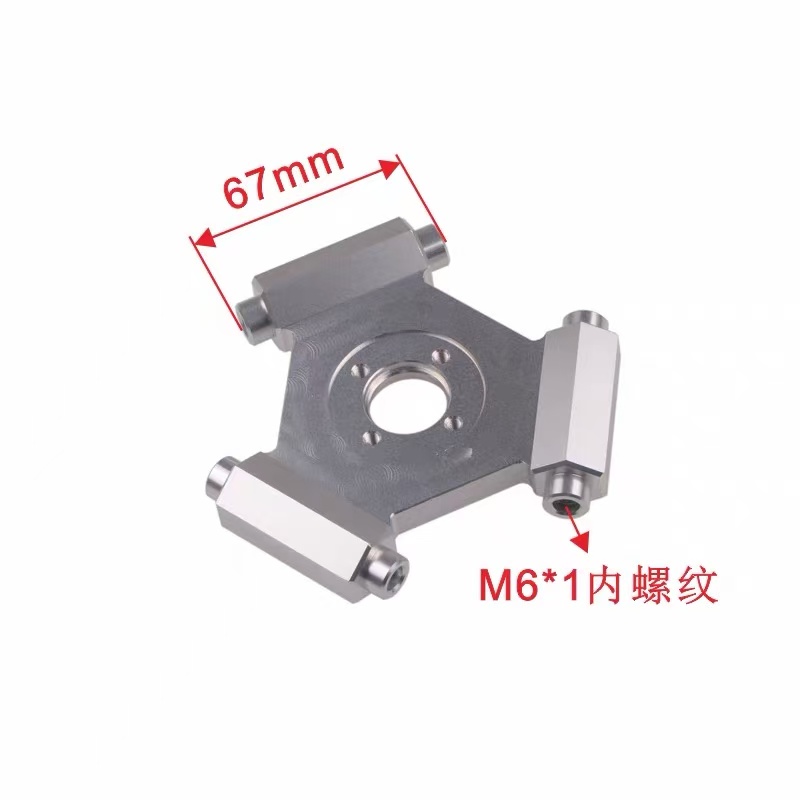
PRE67-M6R